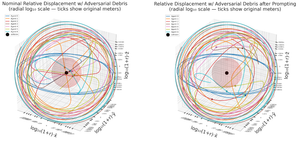
Satellite constellations require orbital transfers that are both fuel efficient and collision avoidant. Yet, the computational cost of optimization methods traditionally used to plan their trajectories scales poorly with both the number of satellites as well as the number of obstacles to avoid, due to the pairwise safety constraints. In this work, we introduce a permutation-equivariant neural operator for trajectory planning of spacecraft swarms. This neural operator maps distributions of spacecraft initial states, target states, and obstacle initial states to trajectories which avoid collision and conserve fuel. This neural operator output is then paired with a batched Gauss-Newton finish to enforce exact orbital dynamics, and further reduce fuel use. The operator is self-supervised, trained without optimal trajectory labels. When trained on ten spacecraft, the proposed method generalized zero-shot to swarms of 1,000 spacecraft and 11,000 obstacles. The generated trajectories matched a per-agent optimal control solver's accuracy while retaining collision avoidance. Operator learning grounded in physics may offer a fast, scalable alternative to trajectory optimization in the increasingly crowded orbits of the future.
publication
Neural Operator Learning for Collision-Aware Trajectory Planning of Spacecraft Swarms
Sidhdharth D. Sikka, Suyi Gao, Zehui Lu, Rongjie Lai, Shaoshuai Mou (2026)
1 min read
Written by
More from Manifold Research
Astra, Opus 5.5, and other Frontier Models Demonstrate Jagged Performance Across SoTA Agentic Tasks from Web Browsing to Robotics
Yangyue Wang, Harshvardhan Sikka, Pranav Guruprasad, Sudipta Chowdhury (2026)
1 min read
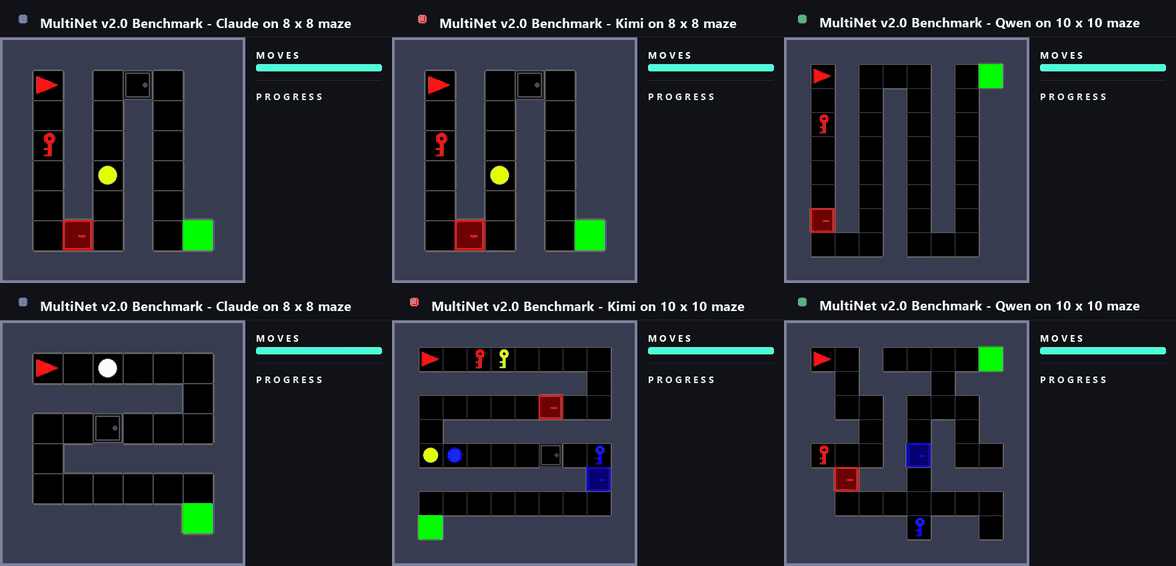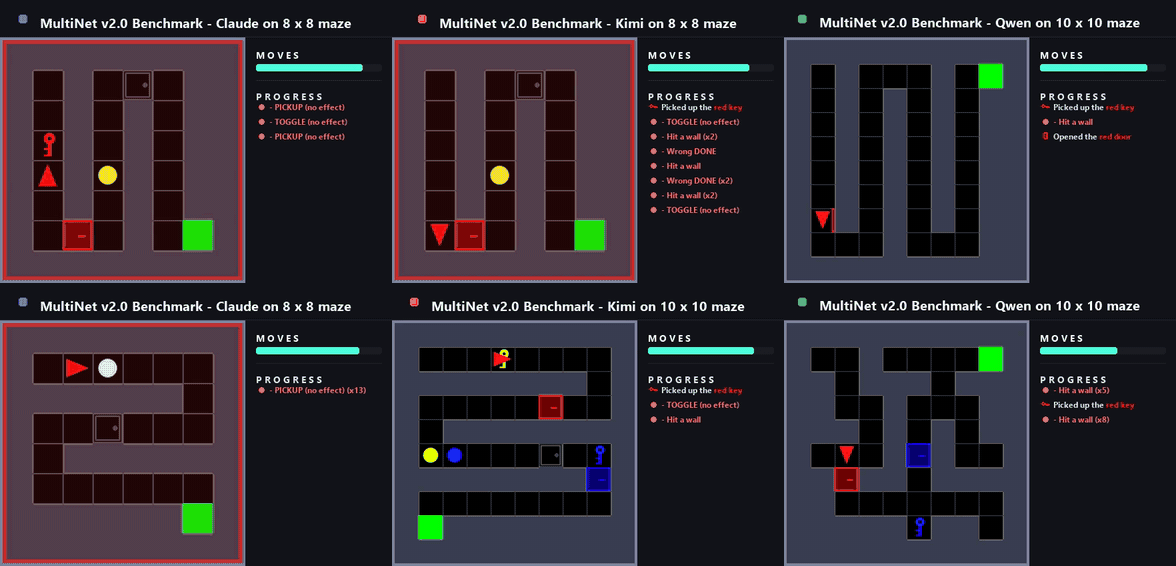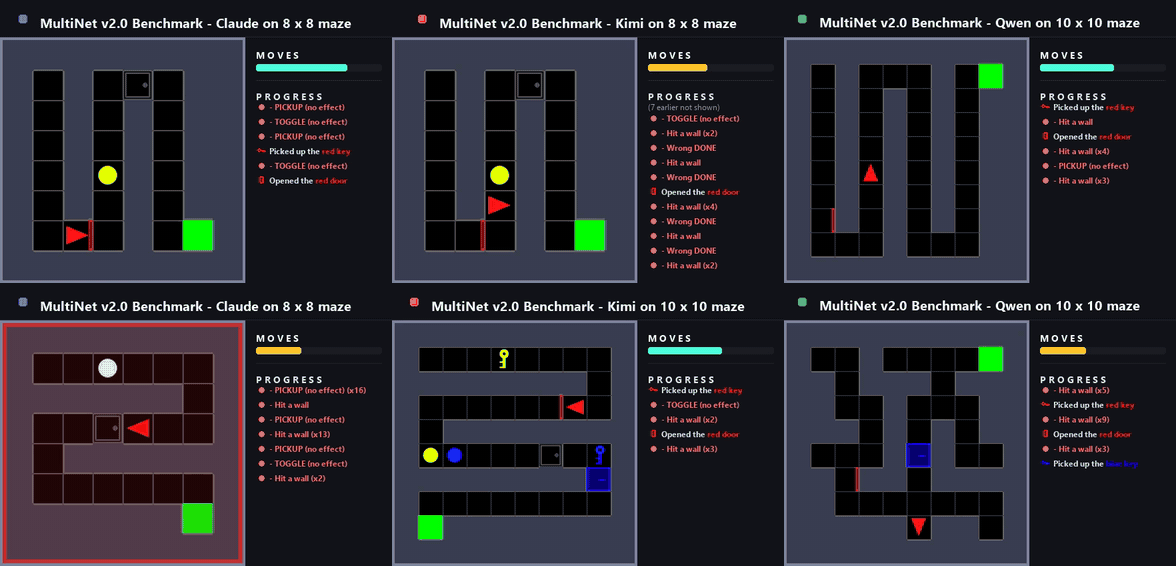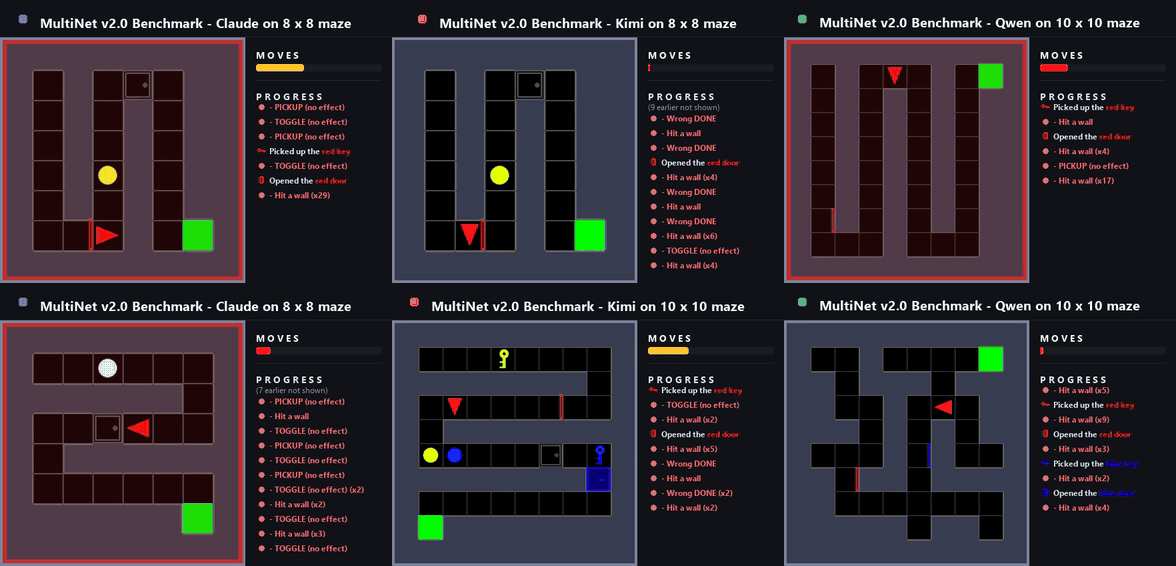
Goal Progress Decays with Task Horizon for Frontier VLMs in Interactive 2D Environments
Pranav Guruprasad, Sean Rivera, Helen Lu, Arushi Jain, Hangliang Ren, Harshvardhan Sikka (2026)
1 min read
Stress-Sharing for Decentralized Fault Repair in Modular Spacecraft
Sidhdharth D. Sikka, Yue Shen, Shaoshuai Mou (2026)
5 min read